Introducing The Quantum Infrastructure CloudLearn more
NavCore™ · Research preview
A second opinion on every GNSS fix.
NavCore checks each GNSS fix against an inertial estimate, flags jamming and spoofing, picks a navigation mode, and writes each flag and mode change to a hash-chained log.
It is a navigation-integrity library inside QCOS, offered as a research preview. The logic is implemented; it has not been tested at sea, in the air or on track, and it holds no type approval.
GNSS vs inertial gate
50 m
C/N0 drop that flags a jam
10 dB
Holdover before denied
300 s
Thresholds set in the code, not measured performance.
NavCore integrity monitor on simulated inputs. No sea trial. Seabed: ETOPO 2022, NOAA NCEI.
The Problem: A Receiver Rarely Says It Is Wrong
GNSS jamming and spoofing are reported by ships and aircraft in several regions. The fix on screen can look normal while it is not.
Drag-Away
A spoofer can move the reported position a little at a time, so no single update looks wrong. Only an independent reference, such as inertial navigation, disagrees.
Silent Degradation
Jamming lowers signal strength and drops satellites. A receiver can keep reporting a position long after it should have stopped being trusted.
Little Record
After an incident, few systems can show what the receiver reported, what was flagged, and when the navigation source changed.
Implemented in Code
What the Code Does Today
Each card says what is implemented and what we found when we replayed the logic on simulated voyages.
No detection rate, false-alarm rate or accuracy figure is published. None has been measured on real signals. The gaps below are OBSERVED by replaying NavCore’s own logic on simulated inputs; real-signal results are TO-VALIDATE in a pilot.
IMPLEMENTED
Spoofing Flags
Raises a spoofing flag when the fix jumps more than 150 m between updates, the receiver clock bias jumps by more than 1,000 m, or the signals arrive suspiciously uniform and strong (spread under 2 dB, mean above 50 dB-Hz).
Gap OBSERVED in simulation: reacquiring after a GNSS outage of about 21 s at 14 kn trips the jump check.
Simulated outage at 14 kn. The returning fix is 180 m from the last one, past the 150 m check, for one update.
IMPLEMENTED
Inertial Cross-Check
Compares each GNSS fix with an inertial position and flags a disagreement above 50 m. Given an independent inertial position, it flagged a simulated 0.5 m/s drag-away once the offset reached 50 m.
Gap OBSERVED in simulation: inside NavCore’s own fusion filter, the position it compares against has already absorbed earlier GNSS fixes, so the same drag-away was never flagged in 15 minutes, 420 m off. Catching drag-away needs an independent inertial reference; TO-VALIDATE on recorded data.
Simulated 0.5 m/s drag-away against an independent inertial position. The status flips while the offset sits at the gate.
IMPLEMENTED
Jamming Flags
Flags a C/N0 drop of more than 10 dB against a rolling baseline, an AGC rise above 20, or the satellite count falling below four.
Gap OBSERVED in simulation: the baseline is the last 10 samples, so a jam that persists becomes the new normal after about 8 s.
Simulated jamming: C/N0 falls, AGC rises, satellites drop.
IMPLEMENTED
Mode Switching
Each update picks a navigation mode: full GNSS, degraded GNSS, inertial-only, or holdover when a jam or spoof is flagged. After 300 s in holdover or inertial-only, the status drops to denied (alert while a threat is still flagged).
The mode is decided again on every update, so one clean update returns to GNSS while the threat may still be present.
Modes from the simulated jamming run, through the 300 s limit.
IMPLEMENTED
Hash-Chained Event Log
Each spoofing flag, jamming flag and mode change is appended to a SHA-256 hash chain. Verification flags an entry whose hashed fields were edited.
Gaps OBSERVED: the chain is not keyed or signed, so an edit with the hashes recomputed from that entry on passes verification, and so does deleting the newest entries. The fault-flag snapshot is not hashed, holdover-limit and sensor faults are not logged, and the chain lives in memory; persistent storage is pilot scope.
The log of the simulated jamming run, verified after each change.
IMPLEMENTED
Integrity Status
Each update also carries a status (nominal, caution, holdover, alert or denied) and the list of active faults, so the operator sees why the mode changed.
Not offered: protection levels. The code’s HPL/VPL fields are a DOP-scaled placeholder, not an integrity computation.
Four updates from the simulated jamming run, as the monitor returned them.
Sensor-Agnostic Inputs
Plain inputs in. Every decision out.
The integrity logic takes GNSS and inertial samples as plain values, so it is not tied to one receiver. There is no receiver driver; connecting a specific receiver is pilot work.
Inputs
GNSS receiver
Position, clock bias, C/N0, AGC, satellites used
Inertial unit
Accelerations and rates for the filter
Recorded logs
The same values replayed from a voyage
NavCore™ integrity monitor
Python library in QCOS
GNSS vs inertial cross-check
Jamming and spoofing flags
Mode switching
Hash-chained event log
Outputs
Navigation mode
Full GNSS, degraded, inertial-only or holdover
Integrity status
With the list of active faults
Event log
Spoofing flags, jamming flags and mode changes, chained by hash
Maritime
First Pilot Domain: Maritime
Integrity checks for vessels that sail through interference
A pilot replays your own recorded GNSS and IMU data through NavCore and reports what it flags, when, and what it misses. No figure is promised before the data is in.
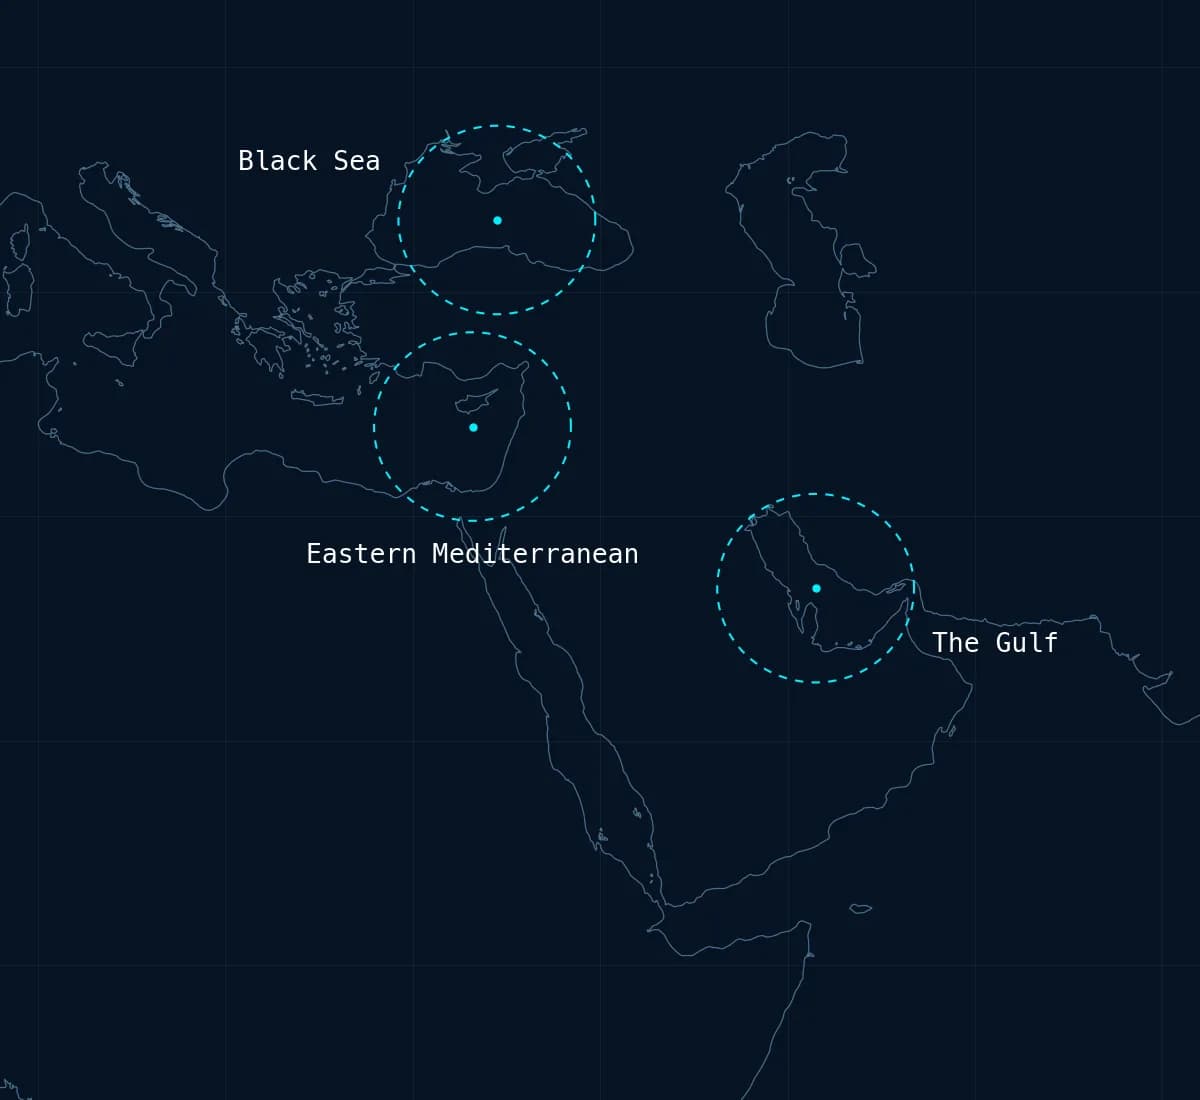
Regions named in the threats list. The rings are labels, not measurements. Coastline: Natural Earth, public domain.
Threats
GNSS jamming and spoofing reported in the Black Sea, the eastern Mediterranean and the Gulf
Slow drag-away that no single update reveals
Little record of what the receiver reported during an incident
What NavCore Runs
Checks: position and clock jumps, C/N0 and AGC, satellite count, and the GNSS vs inertial cross-check
Continuity: full GNSS, degraded, inertial-only or holdover, with a 300 s holdover limit
Record: a SHA-256 hash-chained event log held in memory; persistent storage is pilot scope
What a Pilot Measures
Which of your recorded jamming and spoofing events NavCore flags, and how late
How many flags it raises on clean passages, including after GNSS outages
How far the inertial estimate drifts on your IMU during holdover
Whether the event log answers the questions your incident reviews ask
What NavCore is not: it does not optimise routes, fuel or weather routing, and it does not replace type-approved navigation equipment.
Not in NavCore Today
Listed so nobody buys it for something it does not do.
Capabilities
No Galileo OSNMA authentication. The OSNMA code is research only.
No protection levels and no satellite exclusion.
No receiver drivers and no NMEA or AIS ingest. Connecting a receiver is pilot work.
No hosted API. The integrity monitor runs as a library; it is not served over HTTP today.
No published detection rate, false-alarm rate or accuracy figure, because none has been measured on real signals.
No quantum-sensor integration. The code’s quantum mode is never selected.
Standards and Approvals
NavCore is not certified and holds no type approval. It has not been assessed against IEC 61108, IMO performance standards for navigation equipment, or any aviation or railway standard.
Any standards work would follow a pilot, not precede it.
Have recorded voyage data?
Send us a passage with known interference. We replay it through NavCore and show you every flag, every mode change and every miss.